

Limitations of Forward Collision-Avoidance Assist
Forward Collision-Avoidance Assist may operate abnormally or unexpectedly under the following circumstances:
-
The detection sensor or its surrounding areas are contaminated or damaged.
-
The temperature around the front view camera is extremely high or low.
-
The camera lens is obscured by a windshield tint, film, or coating, damaged glass, or objects on the glass such as a sticker or insect.
-
There is moisture or ice on the windshield.
-
Washer fluid is continuously sprayed, or the wiper is ON.
-
You are driving in heavy rain, snow, or thick fog.
-
Glare from the sun obstructs the front view camera’s field of view.
-
Streetlight or light from oncoming traffic is reflected on the wet road surface, such as a puddle on the road
-
There is an object on the instrument panel.
-
Your vehicle is being towed.
-
The surrounding is very bright, or the surrounding is very dark, such as in a tunnel, etc.
-
The brightness changes suddenly (for example, when you enter or exit a tunnel).
-
The brightness outside is low, and the headlights are not ON or are not bright.
-
Another vehicle or a motorcyclist, pedestrian, or cyclist is only partially visible.
-
The vehicle or powered two-wheeler in front is a bus, heavy truck, truck with an unusually shaped cargo, trailer, etc.
-
The vehicle or powered two-wheeler in front has no tail lights, tail lights are located unusually, etc.
-
The brightness outside is low, and the tail lights are not on or are not bright
-
The rear of the front vehicle is small, or the vehicle does not look normal, such as when the vehicle is tilted, overturned, or the side of the vehicle is visible, etc.
-
The vehicle ahead has ground clearance that is extremely low or high.
-
A vehicle, motorcyclist, pedestrian, or cyclist suddenly crosses ahead of your vehicle.
-
The bumper near the front radar is impacted or damaged, or the front radar is out of position.
-
The temperature near the front radar is high or low.
-
Driving through a tunnel or steel bridge
-
Driving in vast areas where there are few vehicles or structures (for example, desert, meadow, suburb, etc.)
-
Near areas with a lot of metal, like a construction zone or railroad.
-
A material is near that reflects very well on the front radar, such as a guardrail, nearby vehicle, etc.
-
The cyclist in front is on a bicycle made of material that does not reflect on the front radar
-
The vehicle or powered two-wheeler in front is detected late
-
The vehicle or powered two-wheeler in front is suddenly blocked by an obstacle
-
The vehicle or motorcyclist ahead suddenly changes lanes or reduces speed.
-
The vehicle or powered two-wheeler in front is bent out of shape
-
The vehicle ahead is covered in snow.
-
You are departing or returning to the lane.
-
Your driving is unstable.
-
You are driving in a traffic circle and the curvature of the road prevents detection of the vehicle or motorcyclist ahead.
-
You are continuously driving in a circle.
-
The vehicle or powered two-wheeler in front has an unusual shape
-
The vehicle or powered two-wheeler in front is driving uphill or downhill
-
The pedestrian or cyclist is not fully detected, for example, if the pedestrian is leaning over or is not fully walking upright
-
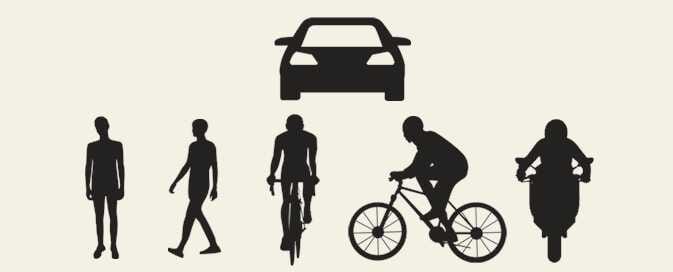 OMV053105
The illustration above shows the image the front view camera and front radar are capable of detecting as a vehicle, powered two-wheeler, pedestrian and cyclist.
-
Wearing clothing or equipment that makes them difficult to detect.
-
Moving very quickly ahead of your vehicle.
-
Short or crouching.
-
Moving opposite of the flow of traffic or having impaired mobility.
-
Part of a large crowd ahead of your vehicle.
-
The pedestrian is wearing clothing that easily blends into the background, making them difficult to detect.
-
Difficult to distinguish from their surroundings.
-
You are driving by a pedestrian, cyclist, traffic signs, structures, etc., near the intersection
-
The system may not detect a pedestrian, motorcyclist or cyclist ahead when you are driving:
-
Through steam, smoke, or shadow.
-
Driving through a tunnel or steel bridge
-
In large areas where there are few vehicles or structures, such as a desert, field, or suburban area.
-
In a parking lot.
-
Through a tollgate, construction area, or rough or bumpy terrain.
-
Near areas with a lot of metal, like a construction zone or railroad.
-
On a steep or curving road.
-
By a roadside with trees or streetlights.
-
Along a narrow road with dense trees or overgrowth.
-
Through electromagnetic waves, such an area with strong radio waves or electrical noise.
-
-
The adverse road conditions cause excessive vehicle vibrations while driving
-
Your vehicle height is low or high due to heavy loads, abnormal tire pressure, and so on.
-
The vehicle is installed with a snow chain, spare tire or different size wheel.
Junction Crossing, Lane-Change Oncoming, Lane-Change Side, Evasive Steering Assist function: (if equipped)
-
The temperature around the front or rear side radar is too high or too low
-
You have installed a trailer or carrier near the rear corner radar.
-
The front or rear corner radar is covered with snow, rain, dirt, and so on.
-
The bumper around front corner or rear corner radar is covered with objects, such as a bumper sticker, bumper guard, bike rack, etc.
-
The bumper near the front or rear corner radar is damaged, or the radar is out of position.
-
The front or rear corner radar is blocked by other vehicles, walls, or pillars.
-
You are driving on a highway ramp.
-
You are driving on a road with a high guardrail or wall.
-
The other vehicle or powered two-wheeler drives very close behind your vehicle, or the other vehicle passes by your vehicle in proximity
-
Another vehicle or motorcyclist passes you at a very high speed.
-
Your vehicle passes another vehicle or motorcyclist.
-
You are accelerating at the same rate as a vehicle or motorcycle in the next lane.
-
A vehicle or motorcycle moves into or out of the lane next to you, or you move into the lane next to another vehicle.
-
The function detects a motorcycle or bicycle.
-
The function detects a flat trailer.
-
The function detects a large vehicle, such as a bus or truck.
-
The function detects a small moving obstacle, such as a pedestrian, animal, shopping cart, or stroller.
-
The function detects a shorter vehicle, such as a sports car.
-
The lane is difficult to see due to foreign material, such as rain, snow, dust, sand, oil and water puddles
-
Lane markings are obscured or not distinct from the road.
-
There are markings on the road near the lane or the markings on the road looks similar to the lane markings
-
The shadow is on the lane marking by a median strip, trees, guardrail, noise barriers, etc.
-
Adjacent lanes end or lane markings merge together.
-
There are more than 2 lane markings on the road.
-
Lane markings are complicated or otherwise affected by roadwork.
-
There are road markings, such as zigzag lanes, crosswalk markings and road signs
-
The lane suddenly disappears, such as at an intersection.
-
The lane is very wide or narrow.
-
There is a curb or road edges without a lane
-
The vehicle ahead is obscuring the lane markings.
-
You are driving very close to the vehicle ahead.
For more information about the limitations of detecting rear corner vehicles and cautions regarding the rear corner sensor, refer to Blind-Spot Collision-Avoidance Assist (BCA).